About
Hi, I am a Ph.D. student at Carnegie Mellon University Robotics Institute working with Prof. Aaron Johnson. I’m interested in developing algorithms for agile locomotion and dexterous manipulation. I’m fortunate to be supported by the NSF Graduate Research Fellowship. During my time here, I’ve also worked with Prof. Sarah Bergbreiter on micro-scale manipulators and design of miniature walking robots.
Prior to joining CMU, I received my B.S. in Mechanical Engineering from the University of California, Santa Barbara, where I worked with Prof. Elliot Hawkes on everting soft robots for industrial inspection and shape-changing robotic collectives. I have also spent summers working at Johns Hopkins University Applied Physics Lab, CMU Robotics Institute Summer Scholars, and SpaceX.

News
- I’m starting my Research Scientist internship at Meta Reality Labs this fall, working on policy learning for dexterous manipulation!
- The project I started as an undergraduate (during RISS) The microDelta: Downscaling robot mechanisms enables ultrafast and high-precision movement was published in Science Robotics !
- I was awarded the National Science Foundation Graduate Research Fellowship (NSF GRFP)!
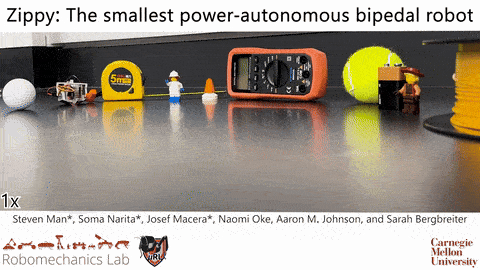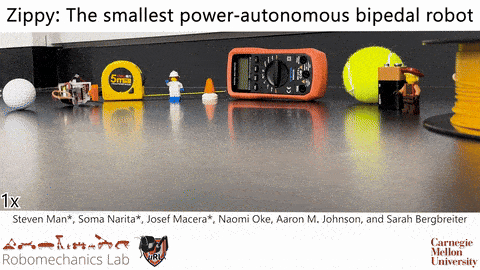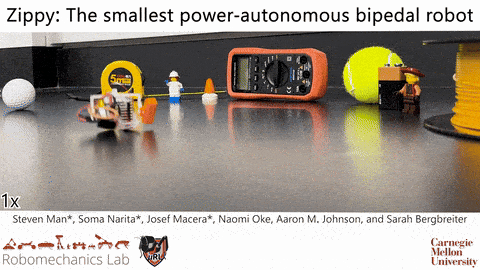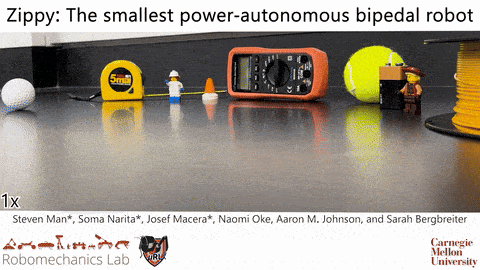
- My paper submission Zippy: The smallest power-autonomous bipedal robot was accepted to International Conference on Robotics and Automation 2025 !
- My undergraduate work Large-Scale Vine Robots for Industrial Inspection: Developing a New Framework to Overcome Limitations With Existing Inspection Methods was published in Robotics and Automation Magazine !
-
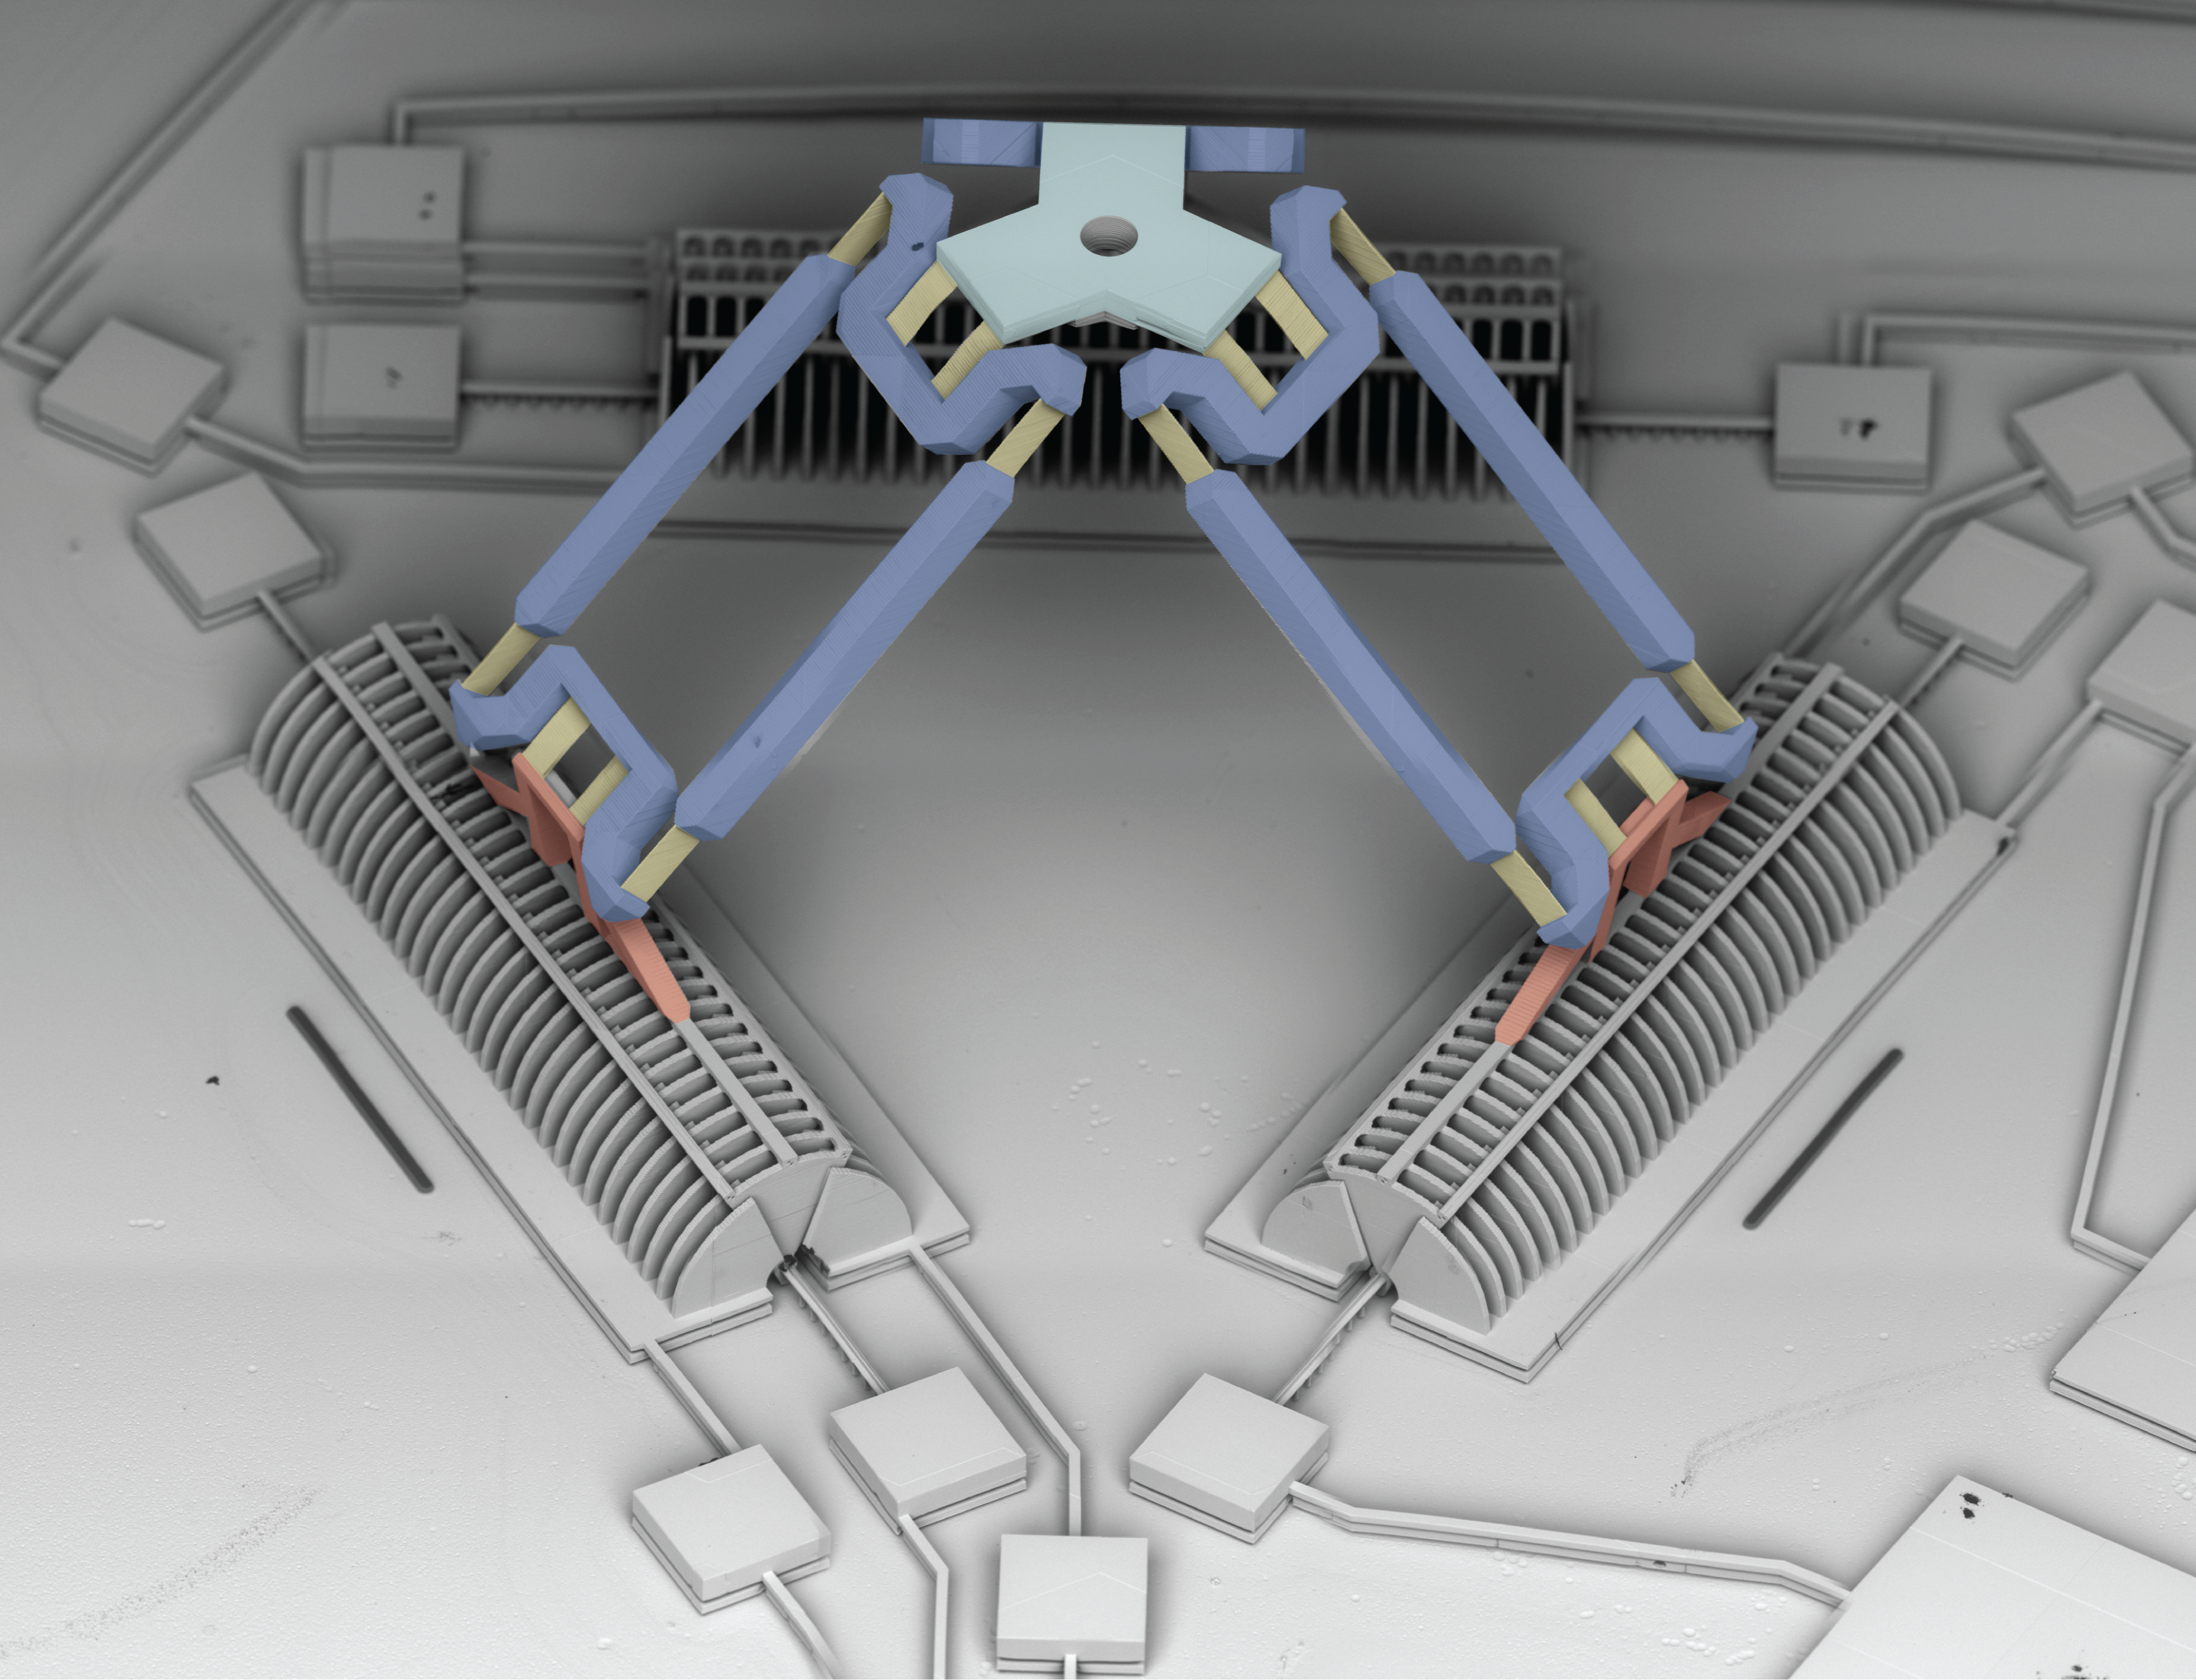 The microDelta: Downscaling robot mechanisms enables ultrafast and high-precision movementScience Robotics, 2025
-
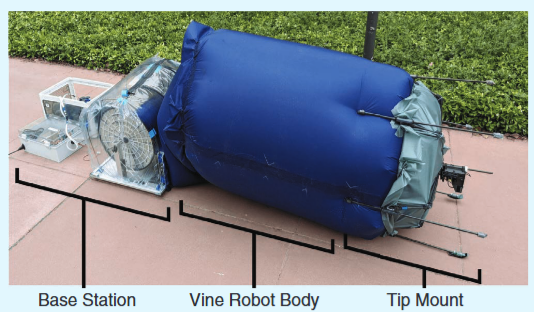 Large-Scale Vine Robots for Industrial Inspection: Developing a New Framework to Overcome Limitations With Existing Inspection MethodsIEEE Robotics & Automation Magazine, 2024